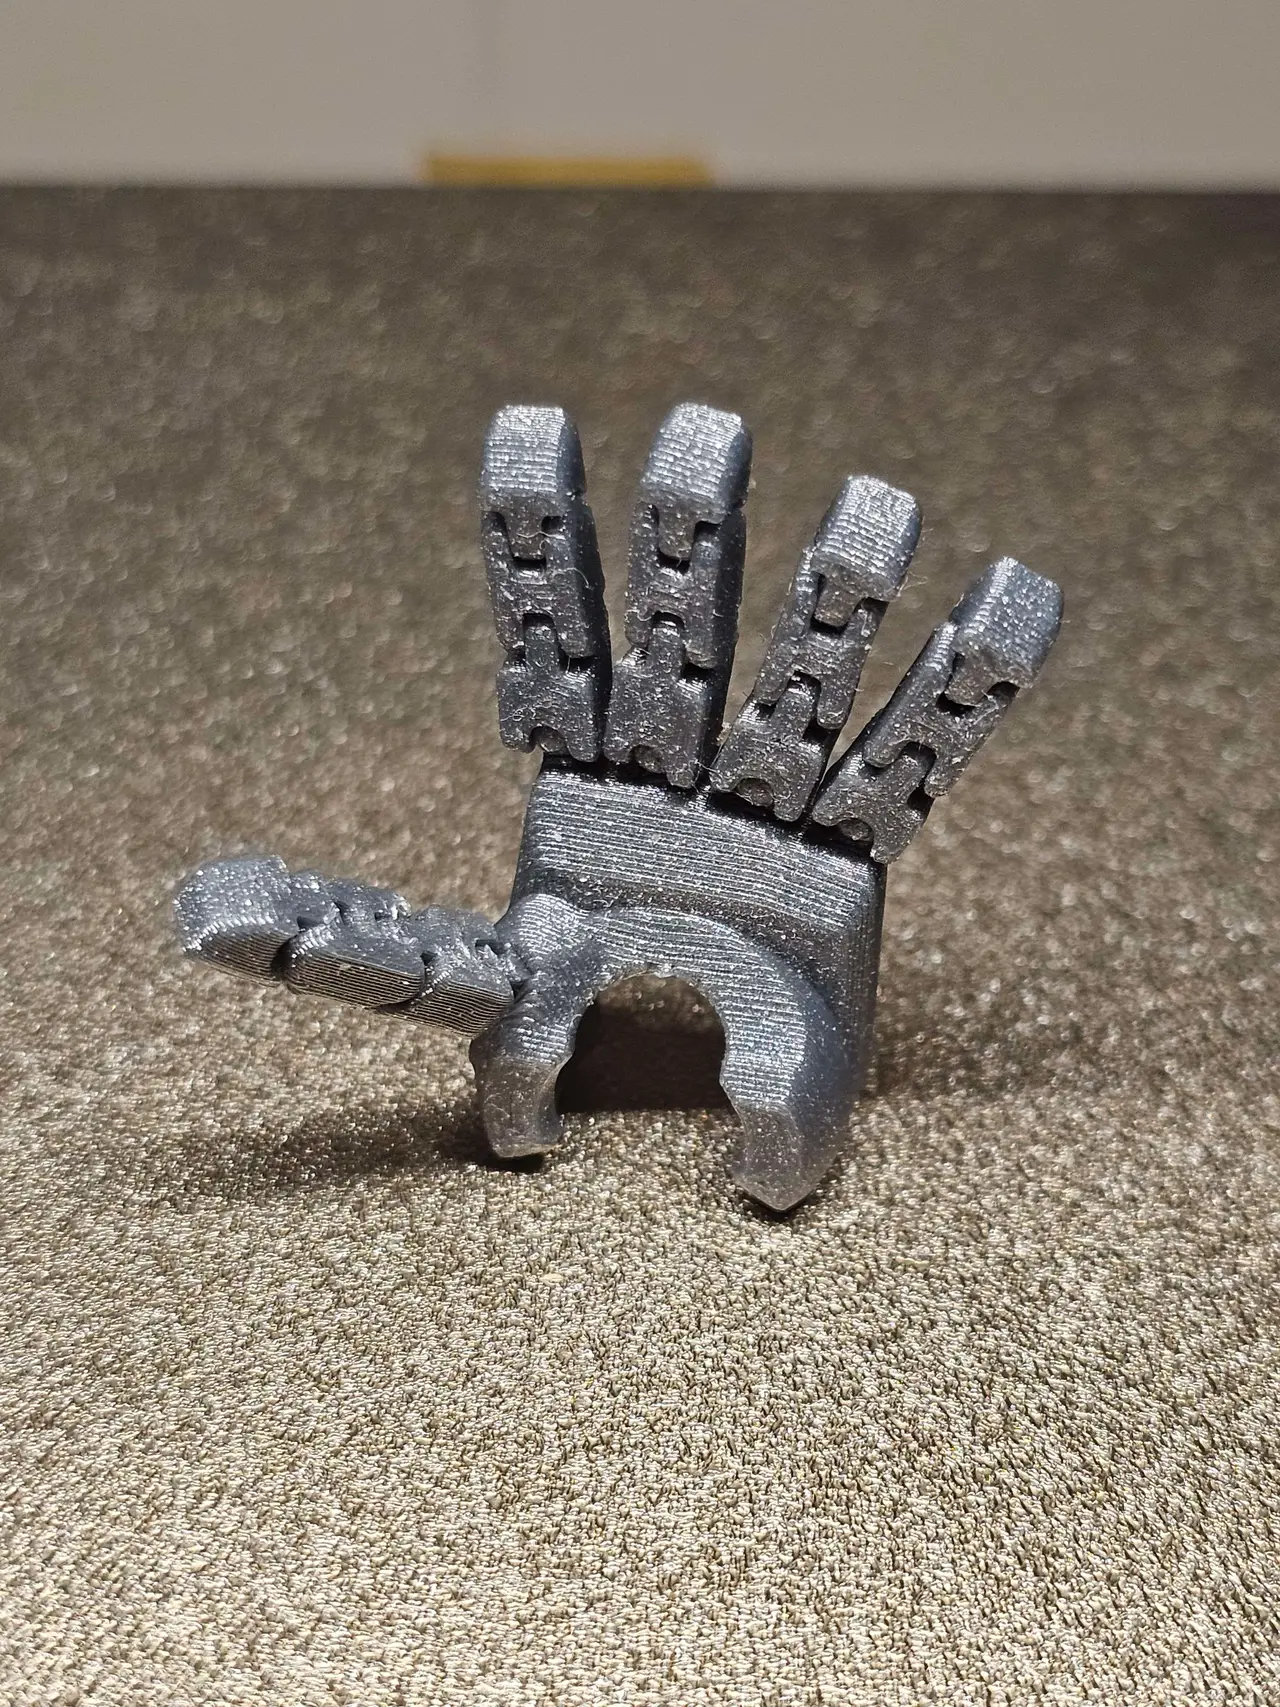
Stronger Poseable hands for 200% scale Dummy 13
por AnniandSteve en Printables
A poseable hand for Dummy 13 with strong joints, easy to print and assemble, plus it's fun to use!
Licencia
Solo uso personalCC BY-NC-SA 4.0 — Atribución, no comercial, compartir igual
Uso personal dando crédito; sin fines comerciales y las modificaciones con la misma licencia.
Al descargar aceptas respetar la licencia y dar crédito a AnniandSteve.
Archivos (3)
- Categoría
- Juguetes y juegos
- Formatos
- 3MF, STL
- Descargas
- 7,167
- Publicado
Sobre este modelo
The other dummy 13 posable hands and fingers didn't work well at 200 percent scale, the fingers were too spaced out, and you couldn't reliably print them with a .4mm nozzle. I used an older model as a guide but I designed these fingers from the ground up to be printed for a 200 percent dummy 13 with .1 layer heights and a .4mm nozzle. They even work with PLA but preferably PETG. They snap together really strongly and don't pull off unless you REALLY try. In one of the pictures I'm holding a single finger tip with pliers and an added a .5kg spool of filament for weight, I could have added more! I spent months redesigning these and making them over and over again to be strong, keep friction, and have a good range of movement. To make the right hand palm, use your slicer to mirror the left hand. I had the best results when I print the palms one by one, but if you can get away with both at once, more power to you! When assembling go really slowly when pushing the fingers onto the palm balls with firm pressure and it helps if they're warm. Once they are on they shouldn't go anywhere. They hold things well and are easily poseable to give some extra personality to your robot. They have good friction and shouldn't get loose.
Descripción original del autor, publicada en Printables.