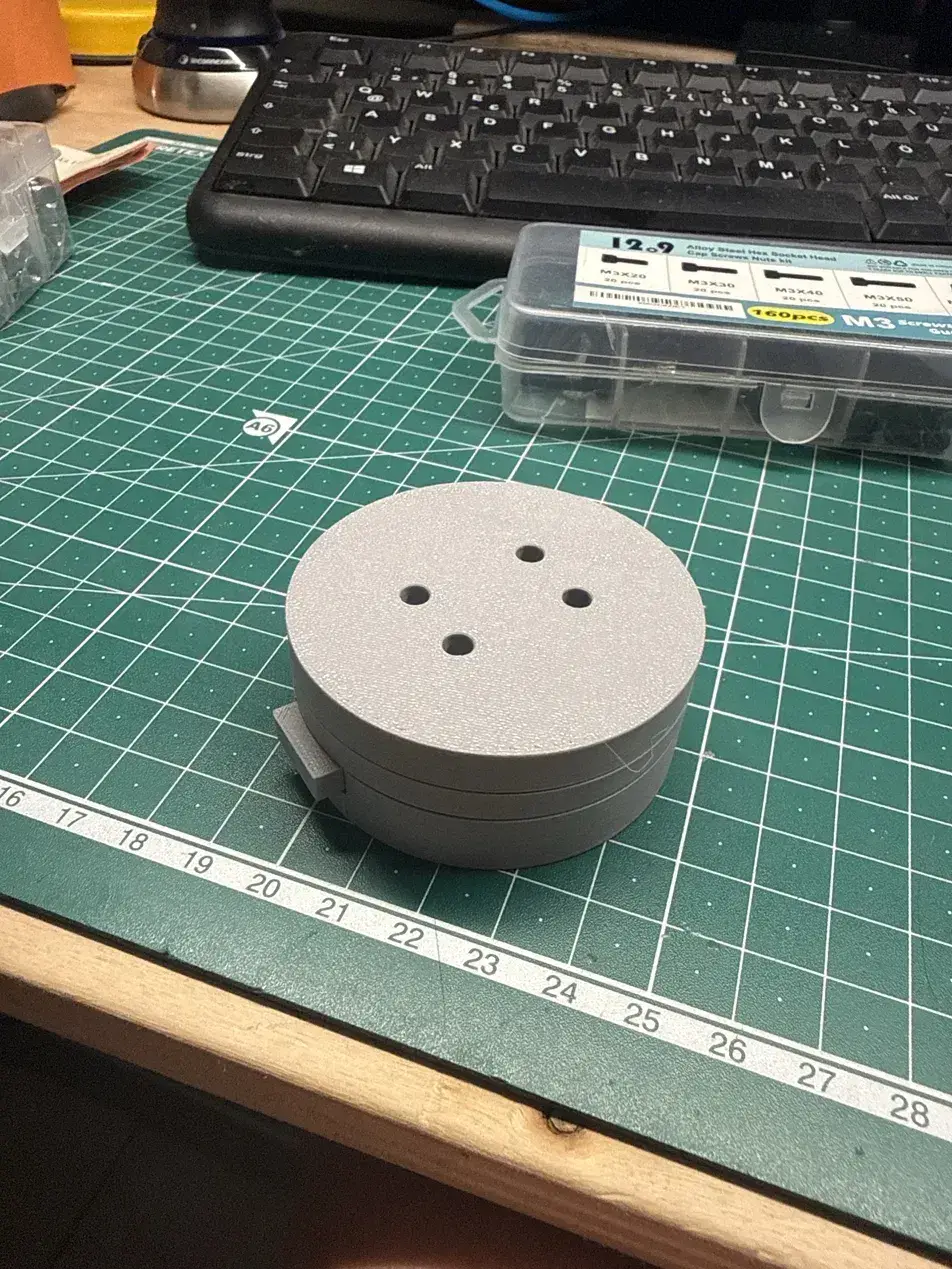
Zero-Point Tool Changer for Faze4 Robot Arm
por Marco Brando en Thingiverse
A printed zero-point quick-change system for the Faze4 6-axis robot arm (J6 flange, 6x M3 on Ø46). Swap grippers in seconds. How it works - Push the tool straight in until it clicks. - A spring-loaded slider with a 20° wedge presses on the shoulder of the pull stud and pulls the tool down into a...
Licencia
Uso comercial permitidoCC BY-SA 4.0 — Atribución, compartir igual
Puedes usarlo y modificarlo dando crédito; las versiones modificadas deben compartirse con la misma licencia.
Al descargar aceptas respetar la licencia y dar crédito a Marco Brando.
Archivos (5)
- Categoría
- Herramientas
- Formatos
- ZIP, STL
- Descargas
- 4
- Publicado
Sobre este modelo
A printed zero-point quick-change system for the Faze4 6-axis robot arm (J6 flange, 6x M3 on Ø46). Swap grippers in seconds. How it works - Push the tool straight in until it clicks. - A spring-loaded slider with a 20° wedge presses on the shoulder of the pull stud and pulls the tool down into a 30° centring cone. - One anti-rotation pin sets the angle. - Press the button to release.
The tool plate fits an SMC MHZ2-16D pneumatic gripper directly (4x M4). Print: PETG, 100 % infill, 0.12–0.16 mm. All STLs are already in print orientation. Support only under the stud head shoulder. Hardware: 6x M3x16 DIN 912, 3x M3x14 DIN 7991 + nuts, 4x M4x12 DIN 912, 1x M3x16 set screw, 1x spring OD 6 x 0.8 x 25 mm. STEP files included for remixing.
Descripción original del autor, publicada en Thingiverse.