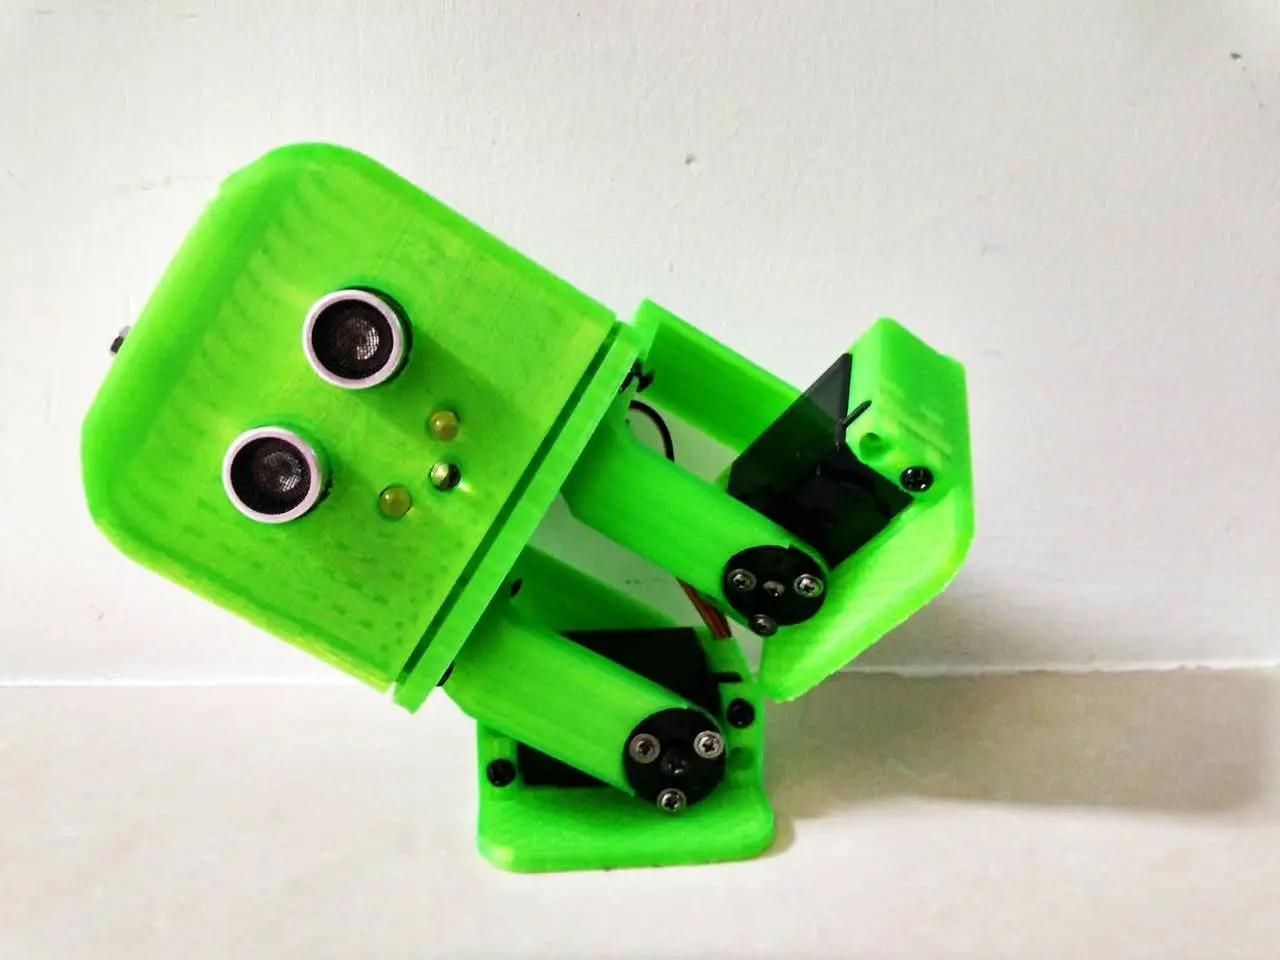
Tito biped robot
por Camilo Parra Palacio en MyMiniFactory
Tito walking and dancer DIY biped robot is a derivative design of Zowi which is based on BOB the original biped robot that uses only 4 servos to walk and move. Made the following improvements:
Licencia
Solo uso personalMyMiniFactory - Credit - Remix - Noncommercial
Licencia de MyMiniFactory: puedes imprimirlo y remezclarlo dando crédito, sin fines comerciales.
Al descargar aceptas respetar la licencia y dar crédito a Camilo Parra Palacio.
Archivos (10)
- 36E86B5367414Fc6Fc974Bee53E551772Bd228D6 Labeled.stl STL
- 5c79a0986e8a2e21e4815c666cd9a99761d89615.stl STL
- 9399b55f70f07b0c4feca1935f3d0503c4ccbed1.stl STL
- a07c054bb33dd0d1023058132bf14c91487e0966.stl STL
- Bba0F6Dbc6B36B7C87F75A46Ff3262A04F6B0C88 Labeled.stl STL
- Tito Base 2.Stl STL
- Tito Foot L 4.Stl STL
- Tito Foot R 3.Stl STL
- Tito Head 1.Stl STL
- Tito Leg V02 5.Stl STL
- Categoría
- Educación
- Formatos
- STL
- Descargas
- 600
- Publicado
Sobre este modelo
Tito walking and dancer DIY biped robot is a derivative design of Zowi which is based on BOB the original biped robot that uses only 4 servos to walk and move. Made the following improvements:
Able to have an Arduino UNO board (or smaller) inside the robot head. 3 LEDs for a simple mouth. Rounded top head. Legs thickness increased and reinforced rounds. Rounded feet top. Chassis - base simplified. Easy to reprogram or energize having the connectors in the back.
Additional Hardware needed: Arduino UNO or compatible, i use a DFRduino R3 Nano breadboard or weld all cables Buzzer Futaba servo S3003 x4 HC-SR04 Ultrasound sensor Nuts M3 x20 Screws M3x12 x20 Powerbank (optional) or just use the usb for power the Arduino board.
Check the schematic picture for connection The HC-SR04 Ultrasound sensor is not connected in the schematic; trig for pin 8 and echo for pin 9)
Using same original code for Arduino: https://github.com/bqlabs/zowi
Descripción original del autor, publicada en MyMiniFactory.