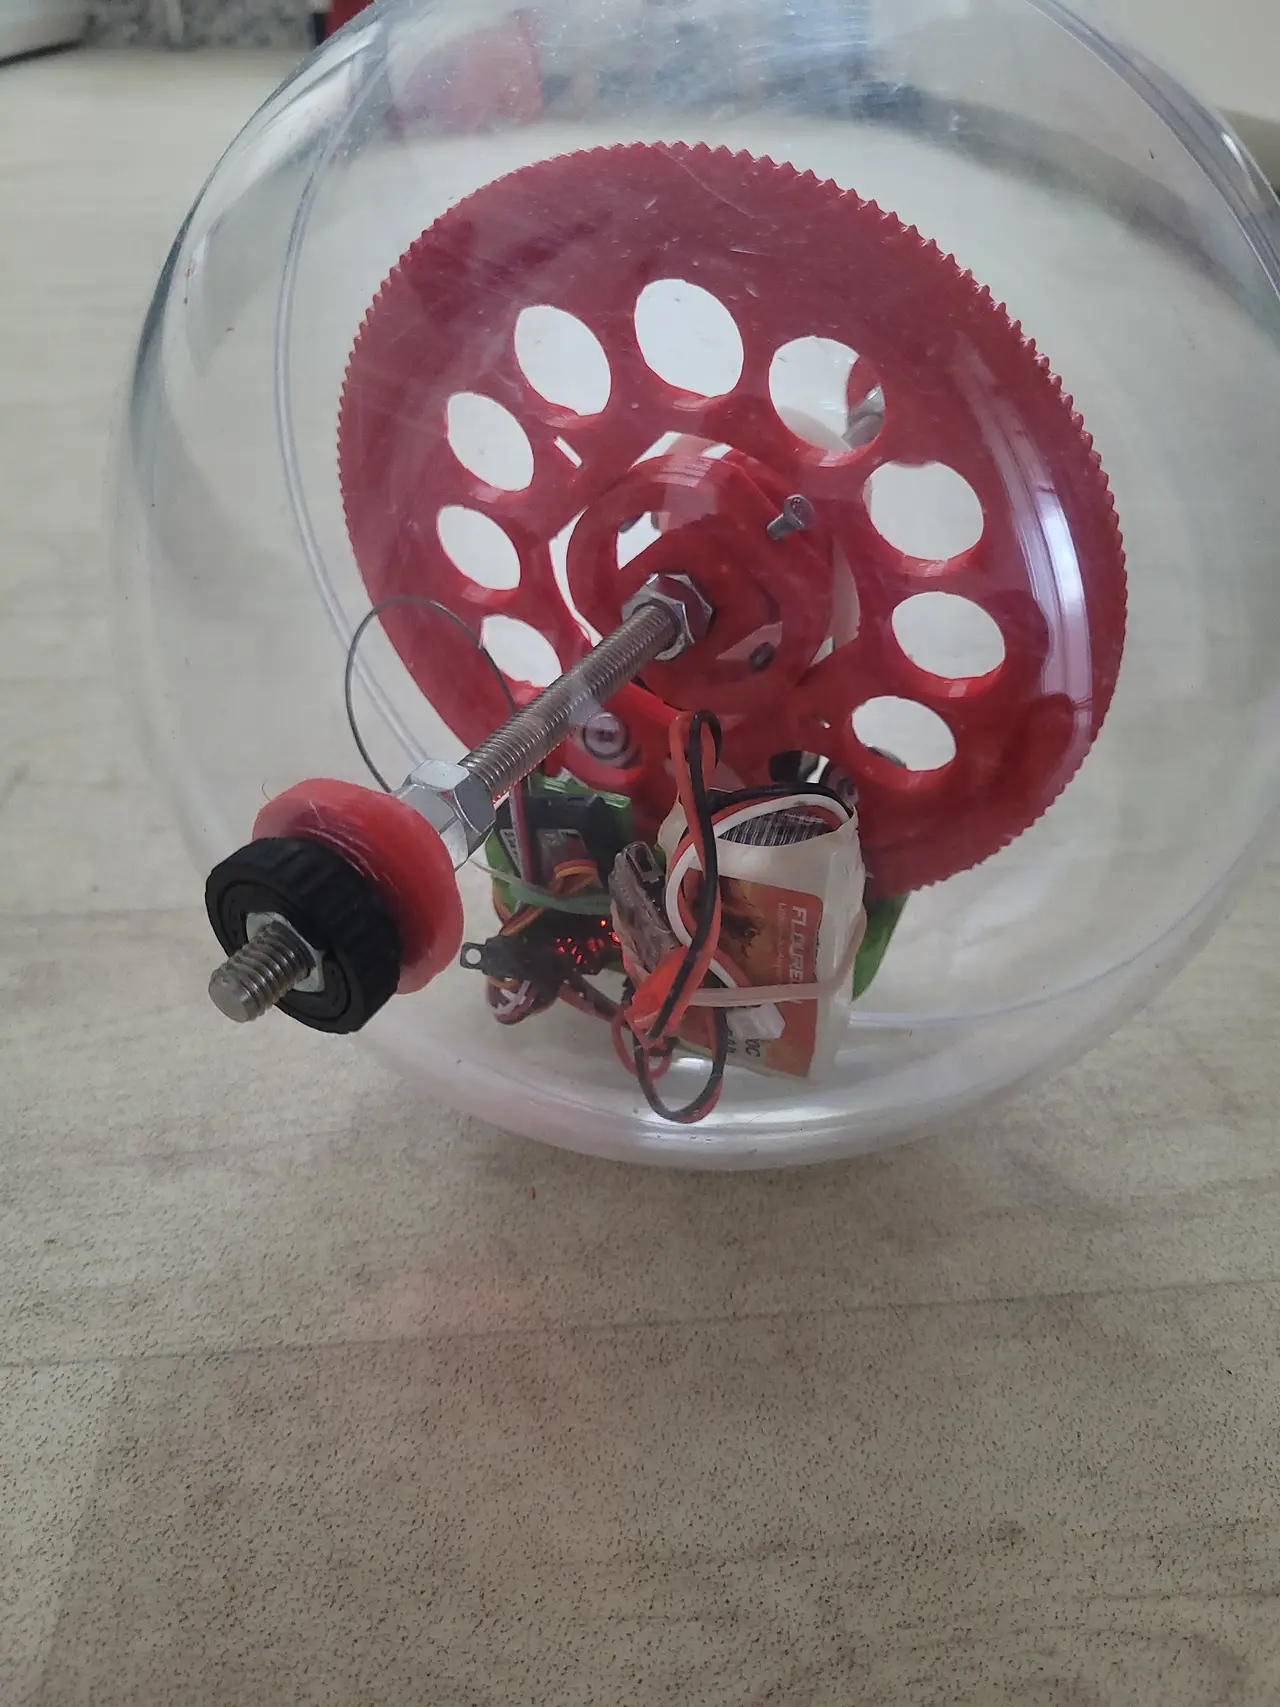
Spherical Robot "Electric Hamster"
por Sebastian Albrecht en Thingiverse
Beacuse spherical robots inhabit a very beautiful symmetry. Why you should not do this: -the acceleration is limited since it relies absolutely on gravity and the center of gravity (CG) cannot be outside the sphere. Even small steps become a problem, since the (CG) would need to overcome the step...
Licencia
Solo uso personalCC BY-NC-SA 4.0 — Atribución, no comercial, compartir igual
Uso personal dando crédito; sin fines comerciales y las modificaciones con la misma licencia.
Al descargar aceptas respetar la licencia y dar crédito a Sebastian Albrecht.
Archivos (13)
- Project_description.pdf PDF · 45 KB
- assy_sphere03.stp STP · 14,3 MB
- sub_gondola-04.stl STL · 87 KB
- sub_gondola-04_1.stl STL · 20 KB
- sub_gondola-04_2.stl STL · 106 KB
- sub_lenkarm02.stl STL · 52 KB
- sub_lenkarm02_1.stl STL · 36 KB
- sub_sphere-con.stl STL · 19 KB
- sub_sphere-con_1.stl STL · 19 KB
- sub_Zahnrad-10.stl STL · 20 KB
- sub_Zahnrad-140.stl STL · 31 KB
- sub_Zahnrad-140_1.stl STL · 42 KB
- sub_Zahnrad-140_2.stl STL · 302 KB
- Categoría
- Repuestos
- Formatos
- PDF, STP, STL
- Descargas
- 2
- Publicado
Sobre este modelo
Beacuse spherical robots inhabit a very beautiful symmetry. Why you should not do this: -the acceleration is limited since it relies absolutely on gravity and the center of gravity (CG) cannot be outside the sphere. Even small steps become a problem, since the (CG) would need to overcome the step outweighing the rest of the sphere (This is what you don’t see in all these videos of spheric robots ...) -swinging and resonance are a problem. -the stability around the vertical axis is zero, since you only have a point-like connection to the floor Luckily, it cannot tip over. It is very hard to control but if you operate it at critical damping velocity and can tolerate a bit of “swing” it is a lot of fun.
Descripción original del autor, publicada en Thingiverse.