Sawppy Six-Wheel Mars Rover (Rocker-Bogie)
por Tom Knox en Thingiverse
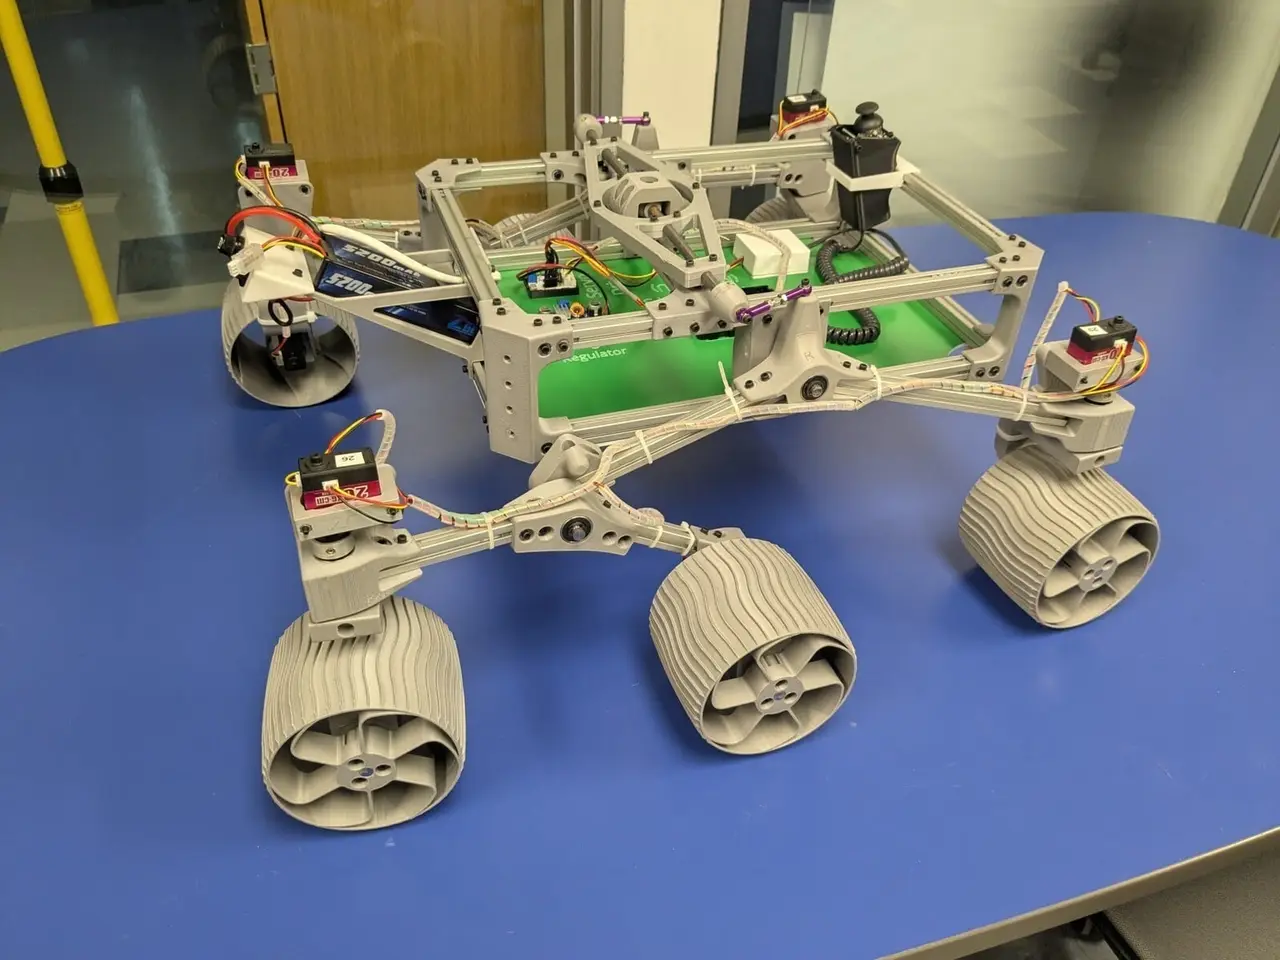
A 3D-printed, motorized model of NASA's Curiosity and Perseverance rovers. Sawppy copies the real rovers' rocker-bogie suspension, so all six wheels stay on the ground over rocks, curbs and garden edges. Four corner wheels steer, which lets the rover turn on the spot. It is a sturdy platform for...
Licencia
Uso comercial permitidoPuedes usarlo, modificarlo y venderlo manteniendo el aviso de copyright del autor.
Al descargar aceptas respetar la licencia y dar crédito a Tom Knox.
Archivos (25)
- Battery_Tray.stl STL · 399 KB
- Sawppy_Mars_Rover_-_Bill_of_Material.pdf PDF · 95 KB
- Body_Corner.stl STL · 1,1 MB
- Bogie-Body.stl STL · 238 KB
- Bogie-Wheels.stl STL · 658 KB
- Clip2n125.stl STL · 7 KB
- Clip3n20.stl STL · 7 KB
- DiffBrace.stl STL · 287 KB
- DiffEnd.stl STL · 468 KB
- DiffLink.stl STL · 178 KB
- DiffLower.stl STL · 269 KB
- DiffUpper.stl STL · 206 KB
- Fixed_Knuckle.stl STL · 449 KB
- Front_Corner.stl STL · 762 KB
- LX-16A_-_Bracket.stl STL · 119 KB
- LX-16A_-_Coupler.stl STL · 160 KB
- Power_Panel.stl STL · 164 KB
- Rear_Corner.stl STL · 736 KB
- Rocker_Body_Mount.stl STL · 639 KB
- Rocker.stl STL · 928 KB
- Rod_Support.stl STL · 202 KB
- Steering_Knuckle.stl STL · 273 KB
- Wheel_Hub.stl STL · 103 KB
- Wheel.stl STL · 1,2 MB
- Sawppy_Mars_Rover_-_Build_Guide.pdf PDF · 69 KB
- Categoría
- Tecnología
- Formatos
- STL, PDF
- Descargas (todas las plataformas)
- 816
- Publicado
También en
Sobre este modelo
A 3D-printed, motorized model of NASA's Curiosity and Perseverance rovers. Sawppy copies the real rovers' rocker-bogie suspension, so all six wheels stay on the ground over rocks, curbs and garden edges. Four corner wheels steer, which lets the rover turn on the spot. It is a sturdy platform for driving around the yard and for your own robotics software later. This is a refurbished remix of Sawppy the Rover by Roger Cheng (https://github.com/Roger-random/Sawppy_Rover). The photos show a community build by Kevin Nickels. Updated for modern use: one purchase list for the whole rover, a print list with counts and mirrored parts, cut lists for the frame and shafts, and one build guide in build order. What you build - A body box of 15 mm aluminum extrusion joined by printed corners and clips - Rocker-bogie suspension on both sides with a differential bar across the body - Six driven wheels, four of them on steering corners - 10 LX-16A serial bus servos on one daisy-chained bus: 6 drive the wheels, 4 steer the corners - Battery tray, power panel with switch, fuse and voltmeter
Files - All 23 print-ready STL files - Build guide PDF: print list, frame and shaft cut lists, actuator modules, wheels, suspension, body, wiring and first drive - Bill of Material PDF with quantities, notes and a shop link for every part
Print settings About 3 kg of PETG for the final rover (PLA is fine for a test fit). 0.4 mm nozzle, 0.2-0.3 mm layers, 3-4 perimeters, 30-40% infill. Small clips and couplers are printed in bulk (88 small clips, 12 large clips, 10 couplers), so print a few spares. Several parts come in left and right versions: print the mirrored copy in your slicer where the print list says so. Electronics - 10 Hiwonder LX-16A serial bus servos and a USB bus servo adapter - Raspberry Pi with a microSD card, fed by a 5 V buck converter - 2S 5200 mAh LiPo battery, 10 A fuse, power switch and voltmeter
Bill of Material Every part you need to buy, with quantities, notes and shop links, is in the Bill of Material PDF in the files of this model. Software Drive it from a phone browser with the SGVHAK rover software on a Raspberry Pi, or use the ESP32 or Arduino sketches from the source files. Give every servo its own ID before you chain them together; the build guide shows the order. Skill level Intermediate. You cut aluminum extrusion and steel rod to length, cut grooves for E-clips, ream 8 mm holes and set heat-set inserts. No soldering beyond the power switch, fuse and battery lead. Full build guide and source The build guide, source and all project files: https://github.com/ToolKnox/hawkridge-sawppy-mars-rover-rocker-bogie (Code > Download ZIP). Safety Use a balance charger and a LiPo bag, keep the fuse between battery and servos, and never leave a charging LiPo unattended. The servos are strong enough to pinch fingers in the steering joints. Sawppy is not waterproof.
Descripción original del autor, publicada en Thingiverse.