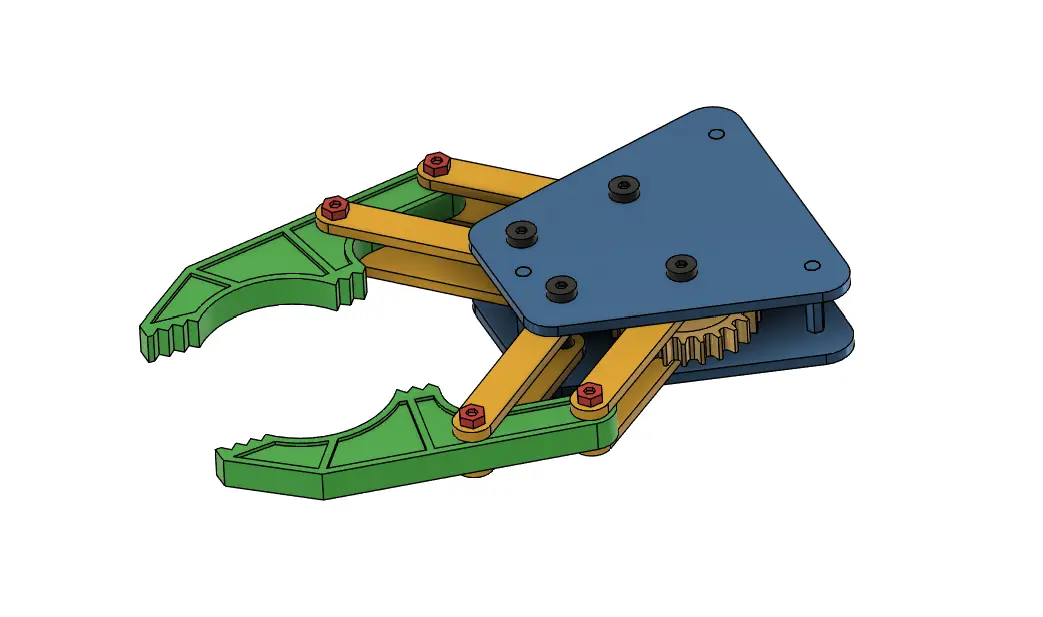
Robotic Arm Gripper (Fully 3D Printable)
por ondrak123k en Printables
Robotic arm gripper, for a robot to grip and hold things! Whole assembly and Fusion file included.
Licencia
Uso comercial permitidoCC BY-SA 4.0 — Atribución, compartir igual
Puedes usarlo y modificarlo dando crédito; las versiones modificadas deben compartirse con la misma licencia.
Al descargar aceptas respetar la licencia y dar crédito a ondrak123k.
Archivos (21)
- Pin STL.stl STL · 51 KB
- Screw STL.stl STL · 75 KB
- Gripper STL.stl STL · 181 KB
- Gear STL.stl STL · 1,3 MB
- Slider STL.stl STL · 74 KB
- Base top STL.stl STL · 199 KB
- Base bottom STL.stl STL · 202 KB
- Gripper simplified STL.stl STL · 79 KB
- Gear simplified STL.stl STL · 1,2 MB
- Screw STEP.step STEP · 18 KB
- Pin STEP.step STEP · 25 KB
- Gripper STEP.step STEP · 91 KB
- Gear STEP.step STEP · 566 KB
- Slider STEP.step STEP · 14 KB
- Base top STEP.step STEP · 26 KB
- Base bottom STEP.step STEP · 55 KB
- Gear simplified STEP.step STEP · 534 KB
- Gripper simplified STEP.step STEP · 35 KB
- Robotic Arm Gripper WHOLE ASSEMBLY STEP.step STEP · 815 KB
- Robotic Arm Gripper FINAL whole project F3D.f3d F3D · 1,7 MB
- Robotic arm gripper, correct orientation, STL.stl STL · 6,6 MB
- Categoría
- Varios
- Formatos
- STL, STEP, F3D
- Descargas
- 3
- Publicado
Sobre este modelo
ROBOTIC ARM GRIPPER - This arm can be used in almost any robotic arm project, as the gripper that picks up/holds items!
- Designed in Fusion (all the files are included).
- Consists of 22 parts. (Base bottom, base top, 2 gears, 8 sliders, 2 grippers, 4 screws, 4 pins)
- The total dimensions are: 170mm x ~85mm x 22mm (length, width, height).
- There are two versions of the gripper and gear (normal - with bridging or simplified - without bridging).
PRINT SETTINGS: - Filament: most reccomended PLA, PETG
- Brim: not required, however can be used on the screw and pin
- Supports: not needed, if your printer cannot handle the bridging cleanly, you can use the simplified versions of the parts
- Walls: 3
- Infill: 10% is enough
- Infill pattern: does not matter, I use grid, gyroid or honeycomb
- Speed: print at normal speeds for the best results
- Layer height: reccomended 0.20mm, or ~0.20mm
- Correct print orientation shown on the image below, or can be downloaded:
ASSEMBLY GUIDE: - Place four of the sliders onto the base of the bottom part.
- Place two of the gears on the top two sliders.
- Place another two sliders on top of the gears.
- Slide the base top part into the base bottom part. You can use glue if the friction isn’t enough.
- Place two more sliders on top of the bottom two sliders.
- Slide the screws (not pins!), into the base top trough all of the parts.
- Slide the grippers into the sliders.
- Now secure the grippers with pins (not screws!). And now you are done!
Descripción original del autor, publicada en Printables.