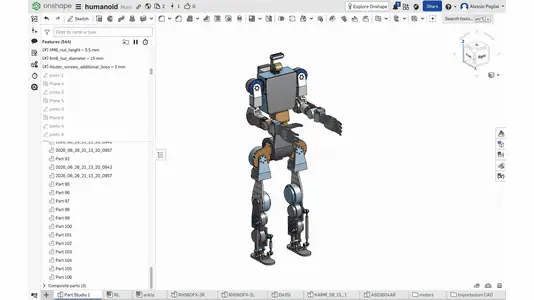
Primo humanoid robot
por 川 en Thingiverse
Primo is an open source humanoid. 3D printed structure in PA-CF, 30 RobStride quasi-direct-drive actuators, NVIDIA Jetson AGX Thor, Unitree G1 kinematics as reference. Height ≈ 1.40 m, ≈ 45 kg. Video, CAD tour and walking in Isaac Lab: https://youtu.be/6nTcHpFmKbQ Still in design, not built yet...
Licencia
Uso comercial permitidoPuedes imprimirlo, modificarlo y venderlo sin pedir permiso ni dar crédito.
Al descargar aceptas respetar la licencia y dar crédito a 川.
Archivos (38)
- ankle-gimbal.3mf 3MF · 93 KB
- leg-test-plate.3mf 3MF · 627 KB
- primo.step STEP · 36,0 MB
- pelvis.stl STL · 472 KB
- ribcage.stl STL · 583 KB
- waist_roll_to_yaw.stl STL · 277 KB
- neck_yaw_to_pitch.stl STL · 212 KB
- head.stl STL · 97 KB
- hip_pitch_to_roll_right.stl STL · 311 KB
- hip_pitch_to_roll_left.stl STL · 311 KB
- hip_roll_to_yaw_right.stl STL · 291 KB
- hip_roll_to_yaw_left.stl STL · 291 KB
- femur_right.stl STL · 385 KB
- femur_left.stl STL · 385 KB
- tibia_right.stl STL · 578 KB
- tibia_left.stl STL · 578 KB
- ankle_crank_upper_right.stl STL · 124 KB
- ankle_crank_upper_left.stl STL · 124 KB
- ankle_crank_lower_right.stl STL · 124 KB
- ankle_crank_lower_left.stl STL · 124 KB
- ankle_gimbal_right.stl STL · 35 KB
- ankle_gimbal_left.stl STL · 35 KB
- foot_right.stl STL · 147 KB
- foot_left.stl STL · 147 KB
- shoulder_pitch_to_roll_right.stl STL · 185 KB
- shoulder_pitch_to_roll_left.stl STL · 185 KB
- shoulder_roll_to_yaw_right.stl STL · 268 KB
- shoulder_roll_to_yaw_left.stl STL · 268 KB
- elbow_right.stl STL · 180 KB
- elbow_left.stl STL · 180 KB
- elbow_pitch_to_forearm_roll_right.stl STL · 322 KB
- elbow_pitch_to_forearm_roll_left.stl STL · 322 KB
- forearm_roll_to_pitch_right.stl STL · 251 KB
- forearm_roll_to_pitch_left.stl STL · 251 KB
- forearm_pitch_to_yaw_right.stl STL · 327 KB
- forearm_pitch_to_yaw_left.stl STL · 327 KB
- wrist_right.stl STL · 149 KB
- wrist_left.stl STL · 149 KB
- Categoría
- Educación
- Formatos
- 3MF, STEP, STL
- Descargas
- 205
- Publicado
Sobre este modelo
Primo is an open source humanoid. 3D printed structure in PA-CF, 30 RobStride quasi-direct-drive actuators, NVIDIA Jetson AGX Thor, Unitree G1 kinematics as reference. Height ≈ 1.40 m, ≈ 45 kg. Video, CAD tour and walking in Isaac Lab: https://youtu.be/6nTcHpFmKbQ Still in design, not built yet. Everything is shared to build it together: CAD, printable STL of the structure, bill of materials with links, electrical scheme, URDF, simulation files, walking policies in Isaac Lab and the handoff to continue the project, also with an AI. Files here: the printed structure as STL (20 parts, left and right, millimetres, design state) and the first print projects as 3MF, the ankle offset gimbal and a leg test plate (femur, hip bracket, tibia). What is bought, motors, hands, battery, computer, screws, is in the bill of materials. CAD: https://cad.onshape.com/documents/2a6d830c153f862229ff478f/w/82c50406ffe66995476ba0a1/e/6ac57dbaf03b523effa40409 Everything else: https://github.com/AlessioPagliai/primo Whole folder: https://storage.googleapis.com/riverfamily/primo/primo.zip Print: PA-CF or PPA-CF, 0.4 nozzle, Bambu Lab H2C. Ankle gimbal 3MF: Bambu PPA-CF, 0.2 mm, 1 wall, 90 % grid infill. Leg test plate 3MF: PLA on an H2S, fit test only. Licence: CC0, public domain.
Descripción original del autor, publicada en Thingiverse.