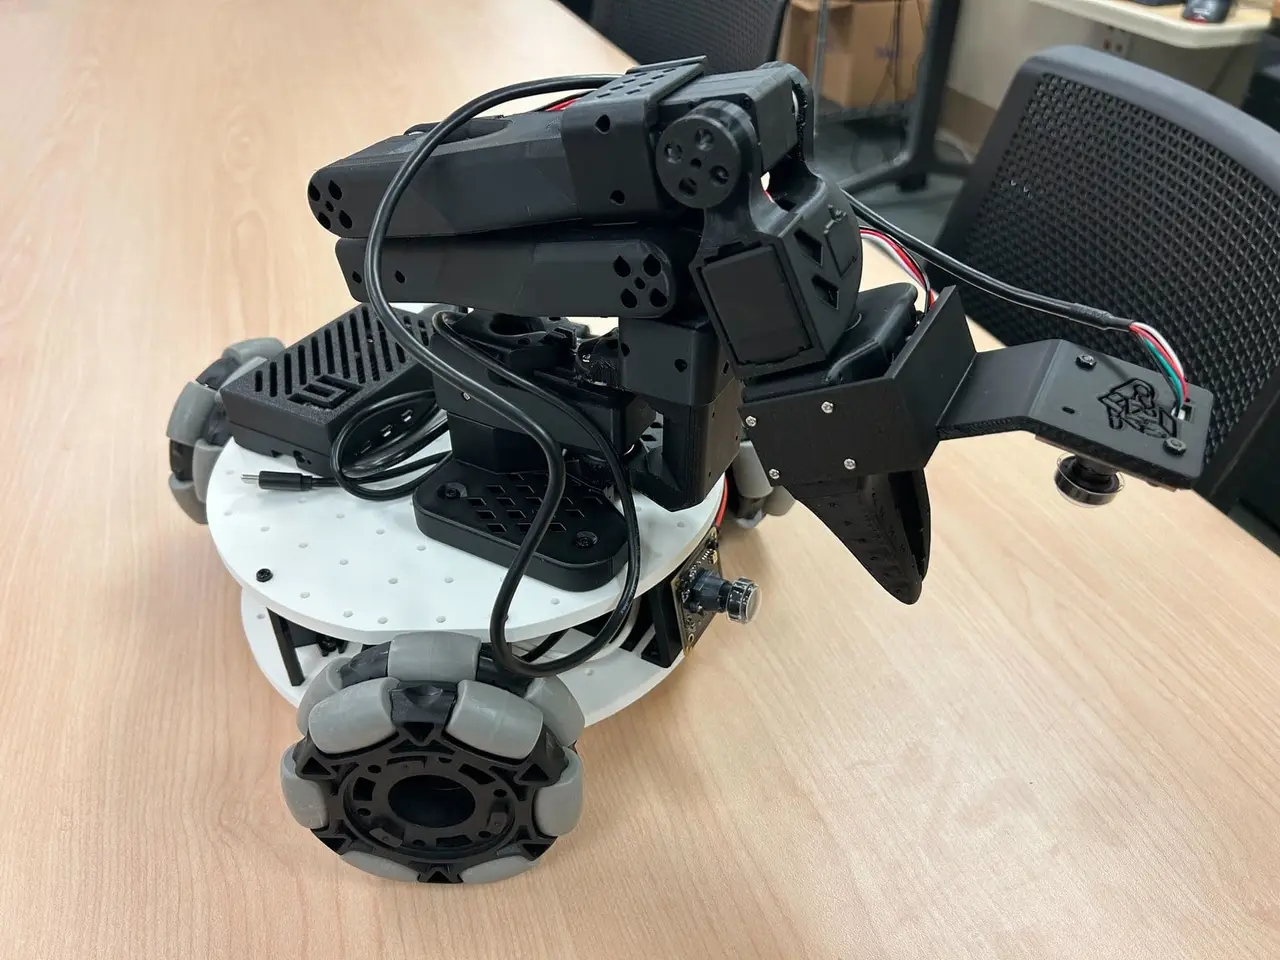
LeKiwi Omni-Wheel Mobile Robot Base
por Tom Knox en Thingiverse
LeKiwi is a small three-wheel robot base that drives in any direction. Three omni wheels sit 120 degrees apart, each turned by a Feetech STS3215 bus servo. A Raspberry Pi 5 runs the robot and streams two camera feeds to your laptop. The top plate carries an SO-101 arm, so the whole thing works as a.
Licencia
Uso comercial permitidoPuedes usarlo, modificarlo y venderlo manteniendo el aviso de copyright del autor.
Al descargar aceptas respetar la licencia y dar crédito a Tom Knox.
Archivos (13)
- 5v_power_bank_holder.stl STL · 18 KB
- base_plate_layer1.stl STL · 461 KB
- base_plate_layer2.stl STL · 478 KB
- drive_motor_mount_v2.stl STL · 415 KB
- modified_base_arm.stl STL · 2,7 MB
- servo_controller_mount.stl STL · 84 KB
- so100_gripper_cam_mount_insert.stl STL · 716 KB
- webcam_mount.step STEP · 79 KB
- webcam_mount.stl STL · 155 KB
- webcam_mount_wrist.step STEP · 107 KB
- webcam_mount_wrist.stl STL · 147 KB
- LeKiwi_Omni-Wheel_Robot_Base_-_Build_Guide.pdf PDF · 67 KB
- LeKiwi_Omni-Wheel_Robot_Base_-_Bill_of_Material.pdf PDF · 59 KB
- Categoría
- Tecnología
- Formatos
- STL, STEP, PDF
- Descargas
- 145
- Publicado
Sobre este modelo
LeKiwi is a small three-wheel robot base that drives in any direction. Three omni wheels sit 120 degrees apart, each turned by a Feetech STS3215 bus servo. A Raspberry Pi 5 runs the robot and streams two camera feeds to your laptop. The top plate carries an SO-101 arm, so the whole thing works as a low-cost mobile manipulator for teleoperation and robot-learning data collection with Hugging Face LeRobot. This is a refurbished remix of LeKiwi by SIGRobotics at UIUC and Hugging Face LeRobot (https://github.com/SIGRobotics-UIUC/LeKiwi). Updated for modern use: one build path (the 5 V power-bank version), a store-bought Raspberry Pi 5 case instead of a printed one, and all parts collected into one shopping list. What you build - Two stacked base plates on a 20 mm grid of 3.5 mm holes, so you can bolt on your own mounts - Three drive motor mounts for 100 mm omni wheels - A holder for a USB-C power bank and a mount for the servo driver board - Webcam mounts for the base and the arm wrist - An optional modified arm base that bolts the SO-101 follower arm to the top plate
Files - Print-ready STL files for the base plates, motor mounts, power bank holder, driver mount, camera mounts and arm base - STEP files for both webcam mounts - Build guide PDF: printing, servo setup, assembly, wiring, cameras and software - Bill of Material PDF with quantities, notes and a shop link for every part
Print settings All parts print in PLA on a normal FDM printer, about 34 hours in total. Use 0.2 mm layers and 15% infill. Print the modified arm base with tree supports. Wheel hubs are not included; this package does not supply a hub. Electronics - Raspberry Pi 5 (4 GB) with a 64 GB microSD card - Three STS3215 servos on a USB bus servo driver board - Two USB webcams - A 20000 mAh USB-C PD power bank feeding the Pi and, through a USB-C to DC cable, the servo driver
Bill of Material Every part you need to buy, with quantities, notes and shop links, is in the Bill of Material PDF in the files of this model. Software The robot runs Hugging Face LeRobot. The Pi hosts the motors and cameras, and your laptop runs teleoperation with the keyboard and an SO-101 leader arm. Full build guide and source The build guide, source and all project files: https://github.com/ToolKnox/hawkridge-lekiwi-omni-wheel-mobile-robot-base (Code > Download ZIP). Safety Keep the robot on the floor or a large table with an edge guard while you tune it. Disconnect the power bank before you rewire the servos.
Descripción original del autor, publicada en Thingiverse.