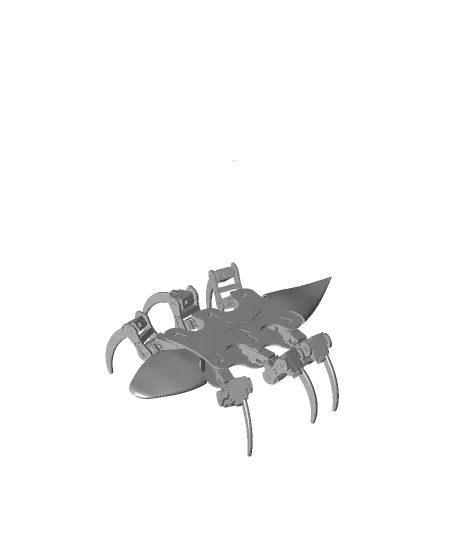
Hexapod Robot Arduino
I wanted to make this project for a long time. Inspired by a projet of HowToMechatronics from a few years ago. This robot is fully 3D printed and is just the first version and is sensorless. In the future I want to add a lot more controls and sensors. This robot has 18 high torque servo motors, runs
Thangs entrega los archivos a usuarios con cuenta gratuita
Licencia
Solo uso personalSin licencia indicada
El autor no indicó una licencia: todos los derechos le pertenecen. Úsalo solo para imprimir en casa y consulta al autor para cualquier otro uso.
Al descargar aceptas respetar la licencia y dar crédito a Andrei A.
Archivos (10)
- 1_Full_robot.stl STL · 85,7 MB
- 1_x_Bottom.stl STL · 623 KB
- 1_x_Head.stl STL · 1,5 MB
- 1_x_Tail.stl STL · 2,2 MB
- 1_x_Top.stl STL · 630 KB
- 6_x_Join.stl STL · 52 KB
- 6_x_Leg_A.stl STL · 500 KB
- 6_x_Leg_D.stl STL · 476 KB
- 12_x_Leg_B.stl STL · 174 KB
- 12_x_Leg_C.stl STL · 212 KB
- Categoría
- Tecnología
- Formatos
- STL
- Descargas
- 53
- Publicado
Sobre este modelo
I wanted to make this project for a long time. Inspired by a projet of HowToMechatronics from a few years ago. This robot is fully 3D printed and is just the first version and is sensorless. In the future I want to add a lot more controls and sensors. This robot has 18 high torque servo motors, runs with an Arduino MEGA and is controlled by Bluetooth with commands from a smartphone. I've made a simple App to control it. See the part list, the 3D printed files, the code and all you need in this tutoprial step by step. Video Tutorial: https://www.youtube.com/watch?v=HRC5HrN8KD0 Schematic: http://electronoobs.com/eng_robotica_tut17_sch1.php Each leg needs 7 3D printed parts as you can see below. Get all STL files from this link and print the parts using PLA material. I've used a 0.4mm nozzle, 0.3mm layer height and 20% infill. We need no support and all parts are already oriented and ready for print. So, get the 7 parts for one leg.
Descripción original del autor, publicada en Thangs.