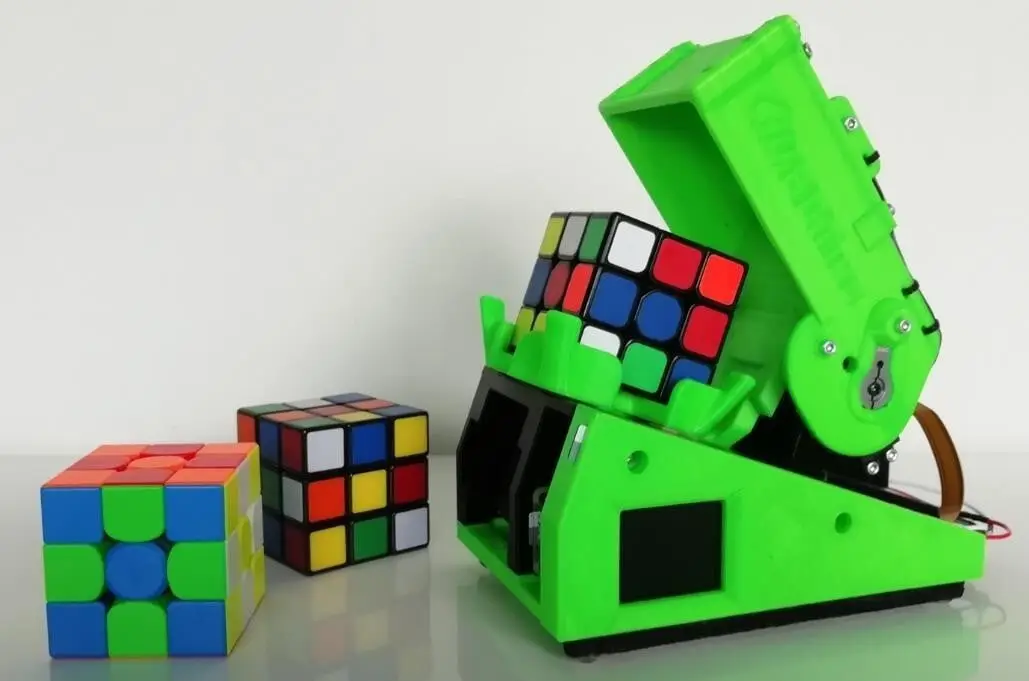
CUBOTino Autonomous Rubik's Cube Solving Robot
por Tom Knox en Thingiverse
CUBOTino is a compact robot that solves a scrambled 3x3 Rubik's cube on its own. A Pi Camera reads all six faces, a Raspberry Pi Zero 2 W works out the solution, and two servos flip and turn the cube until it is solved. A small screen shows the progress, and one touch on the pad starts a new solve..
Licencia
Uso comercial permitidoPuedes imprimirlo, modificarlo y venderlo dando crédito al autor.
Al descargar aceptas respetar la licencia y dar crédito a Tom Knox.
Archivos (22)
- Alternative_Servo_axis_inf.stl STL · 1,1 MB
- Alternative_Servo_axis_sup.stl STL · 1,1 MB
- Baseplate_front.stl STL · 4,8 MB
- Baseplate_rear.stl STL · 3,7 MB
- Cube_holder.stl STL · 15,0 MB
- Extension_left.stl STL · 913 KB
- Extension_middle.stl STL · 3,9 MB
- Extension_right.stl STL · 2,3 MB
- Hinge.stl STL · 8,3 MB
- Lifter.stl STL · 3,2 MB
- PCB_cover_display.stl STL · 7,6 MB
- PCB_cover_display_UsbC.stl STL · 6,2 MB
- Personaliz_plate.stl STL · 80 KB
- Personaliz_plate_01.stl STL · 589 KB
- PiCamera_holder_V1_V2_V3.stl STL · 3,9 MB
- Picamera_holder_frame.stl STL · 6,5 MB
- Servo_axis_inf.stl STL · 222 KB
- Servo_axis_sup.stl STL · 739 KB
- Structure.stl STL · 18,3 MB
- Top_cover.stl STL · 20,6 MB
- CUBOTino_Cube_Solving_Robot_-_Build_Guide.pdf PDF · 66 KB
- CUBOTino_Cube_Solving_Robot_-_Bill_of_Material.pdf PDF · 82 KB
- Categoría
- Tecnología
- Formatos
- STL, PDF
- Descargas (todas las plataformas)
- 291
- Publicado
También en
Sobre este modelo
CUBOTino is a compact robot that solves a scrambled 3x3 Rubik's cube on its own. A Pi Camera reads all six faces, a Raspberry Pi Zero 2 W works out the solution, and two servos flip and turn the cube until it is solved. A small screen shows the progress, and one touch on the pad starts a new solve. No PC is needed once it is set up. This is a refurbished remix of CUBOTino Autonomous by Andrea Favero (https://github.com/AndreaFavero71/cubotino). Updated for modern use: one purchase list for the whole robot, a combined print table with the variant parts and a shorter build guide in build order. The print files are unchanged. What you build - A printed frame with a rotating cube holder on the bottom servo and a flipping top cover on the top servo - A Raspberry Pi Zero 2 W with a Pi Camera on a printed holder looking down at the cube - A 1.77 inch colour display and a touch pad on the front cover - A 3 W LED that lights the cube evenly for the colour scan - A small connections board on prototype PCB, with micro-USB or USB-C power
Files - All 20 print-ready STL files, including the alternative servo axes, the USB-C display cover, two name plates and the optional extensions for a full-size Raspberry Pi - Build guide PDF: print table, electronics, assembly order, software setup and tuning - Bill of Material PDF with quantities, notes and a shop link for every part
Print settings PETG recommended, PLA works. About 700 g of filament and 50 hours of printing in total. The largest part, Structure, fits a 200 x 200 mm bed. Print one of each part; pick the servo axes, display cover and name plate that match your build. The extensions are only needed for a full-size Raspberry Pi. Electronics - Raspberry Pi Zero 2 W with headers, 16 GB microSD and a small heat sink - Pi Camera (V1.3, V2 or V3) with a 30 cm Pi Zero camera cable - 1.77 inch 128x160 SPI display (ST7735) - Two 25 kg metal-gear servos with 25T metal arms; 270 degree servos with a 500-2500 us range are the easiest choice - 3 W LED module, TTP223 touch pad, AMS1117-3.3 regulator and three 220 uF capacitors - Two micro-USB breakouts with two 2 A chargers, or one USB-C breakout with one 3 A charger
Bill of Material Every part you need to buy, with quantities, notes and shop links, is in the Bill of Material PDF in the files of this model. Software Install Raspberry Pi OS on the Zero 2 W, connect over SSH and run the CUBOTino installer from the original project. Then use the servo tuning GUI to set the open, close, flip and rotate positions, and set up the camera. Use a cube with a 56.0-57.5 mm side; average solve time, scan included, is about 90 seconds. Skill level Intermediate. You solder a small connections board on prototype PCB, set up a Raspberry Pi over SSH and tune two servos with a GUI. Full build guide and source The build guide, source and all project files: https://github.com/ToolKnox/hawkridge-cubotino-autonomous-rubiks-cube-robot (Code > Download ZIP). Safety Servos can pinch fingers. Keep hands away from the top cover while the robot runs, and power it from adequate chargers only.
Descripción original del autor, publicada en Thingiverse.