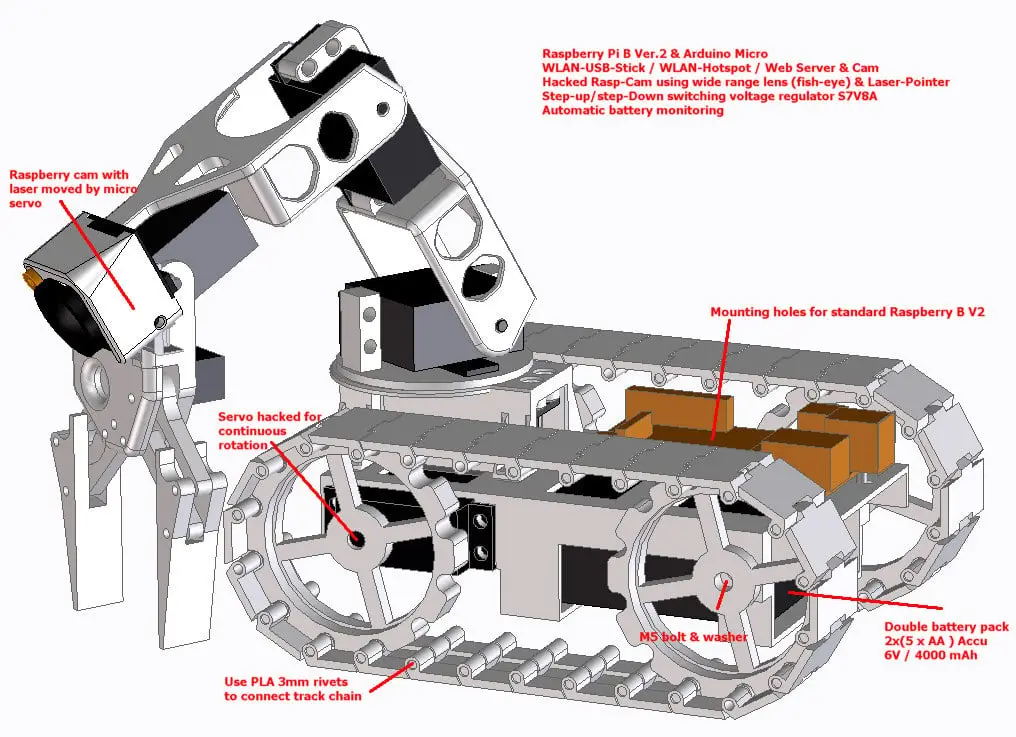
Autonomous-Webserved-Tanktrack-Robot
por donboy en Thingiverse
Start a new project merging several skills in one task. This is my tank track robot controlled by a Raspberry Pi using a webservice. You can control the robot over dynamic website with webcam view. The RSPI also provides RPI-Wireless-Hotspot, so it is possible to connect directly with your...
Licencia
Solo uso personalCC BY-NC 4.0 — Atribución, no comercial
Puedes imprimirlo y modificarlo para uso personal dando crédito. No se permite vender las impresiones.
Al descargar aceptas respetar la licencia y dar crédito a donboy.
Archivos (24)
- CamMount.stl STL · 221 KB
- CamHousing.stl STL · 748 KB
- GripperGuidance.stl STL · 69 KB
- GripperDriveRight.stl STL · 99 KB
- GripperDriveLeft.stl STL · 104 KB
- GripperBase.stl STL · 119 KB
- Arm.stl STL · 444 KB
- GripperLid.stl STL · 142 KB
- TurnTable.stl STL · 104 KB
- Track.stl STL · 147 KB
- GripperJaw.stl STL · 137 KB
- TurnTableBase.stl STL · 273 KB
- Wheel.stl STL · 317 KB
- Chassis2.stl STL · 274 KB
- TrackConstruct.dxf DXF · 103 KB
- Cam2Mount.stl STL · 110 KB
- Cam2Base.stl STL · 146 KB
- Cam2Cover.stl STL · 622 KB
- CableGuide2.stl STL · 458 KB
- CableRedirect2.stl STL · 20 KB
- CableRedirect1.stl STL · 1,3 MB
- BatteryPack_end.stl STL · 200 KB
- BatteryPack_middle.stl STL · 323 KB
- Track_1_75.stl STL · 823 KB
- Categoría
- Tecnología
- Formatos
- STL, DXF
- Descargas
- 26,542
- Publicado
Sobre este modelo
Start a new project merging several skills in one task. This is my tank track robot controlled by a Raspberry Pi using a webservice. You can control the robot over dynamic website with webcam view. The RSPI also provides RPI-Wireless-Hotspot, so it is possible to connect directly with your smartphone. An Arduino-Micro communicates to the RSPI over I2C and controls 8 servos. Also a battery state monitor is implemented. I decide to use standard AA Accus for powering with 2 rows a 5x 1,2 volt. A step-up/ step-down switching voltage regulator guaranteed 5 volt supply despite low battery. See latest video on: https://www.youtube.com/watch?v=D2brukbh378 Updates: 03/12/18: Due to frequent questions: the servo is a MODELCRAFT BMS-410C. You can buy this in Europe at Conrad (https://www.conrad.de/de/modelcraft-standard-servo-bms-410c-analog-servo-getriebe-material-kunststoff-stecksystem-jr-404753.html). The servo is therefore interesting, because he has a receptacle for the axle in the rear housing insinde ! 01/04/16: After a long break, I return to the project again. The Raspberry Pi 3B has now integrated Bluetooth and FiFi which means it has more performance and i can remove the "Ampere-eating" WiFi-Stick. Also checking the use of adressable digital servos or selfmade Digital2PWM-Adaptor for serial (BUS) connection. My intention is reducing the amount of cable to the arm. 07/07/15: Project goes on. Currently, the main problem is the power, respectively the duration of the battery power supply. 1 camera, 8 servos, 2 controller, web service, and Wi-Fi hotspot consume a total of 2.5 amperes. Maybe I wanted to solve too much at once :-(( My aim is: Remote-controlled robot with camera. Looking for an alternative video transmission system without web service 02/26/15: Add Tank-Track for 1.75mm Filament rod. 02/05/15: Software implemented. RSP used as WLAN Hotspot with Webserver -> communicates to Arduino over serial - Arduino over I2C to PCA9685. RSPI won't work in Multislave I2C Mode :-(( 01/21/15: Fault in the electrical circuit improved. MOSFET got too little voltage on UGS -> reduced resistance 01/20/15: Build new Battery-Pack for more current available. Using 16 x AA á 6V (4 x 4 pack) 01/19/15: Implements PCA9685. Works fine! First trial without RSP for verfication of trigonometric calculation on Arduino. 01/08/15: First trial completed. Built a experimental arrangement with a old joystick and a second Arduino-Micro which simulates the RSPI-I2C communication (see image). ARGHH! Huge twitching of the servos because Arduino is overloaded with I2C and 8 servos! Special servo driver ordered (Adafruits-PCA9685) to save Arduino-Performance. 01/06/15: Add layout extension board preview. Not checked if all works - release of eagle file after validation by function. 12/28/14: Laser pointer moved to the middle of the gripper - now i can point to the thing i want to grip exactly. -Change cam to a RSPI-Wide-Angle Cam. In fact this camera is much lighter than the first one! -Change arm wiring! Because of problems with bending and buckling the wires between the servos i decide to route them on the side which made it necessary to implement the cam to the other side. So add 2 additional cable guides. (see new images) 12/21/14: The chassis is wide enough now.It is not necessary to desolder the cinch video connector. This is a work-in-progress project and wil bee updated regularly ;-)
Descripción original del autor, publicada en Thingiverse.