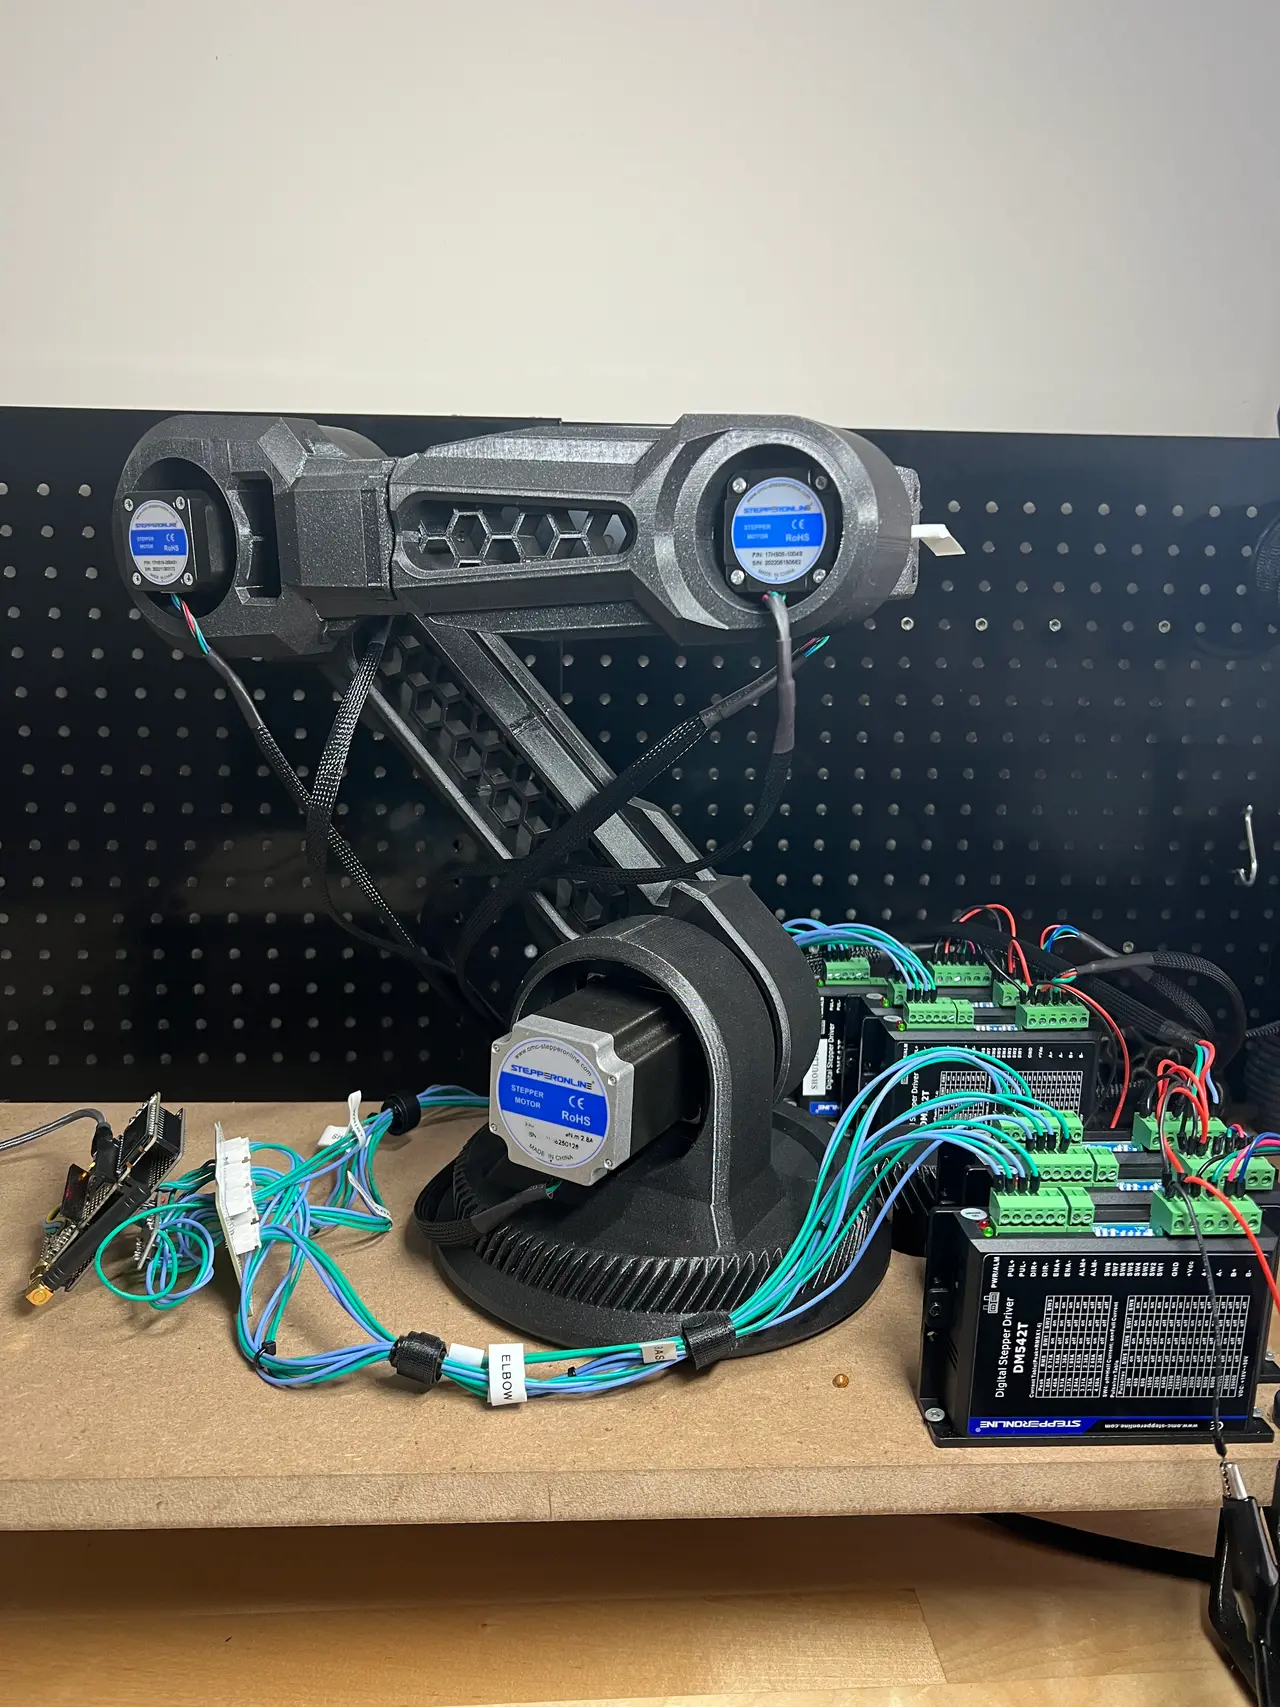
6-Axis Robotic Arm
por Event Horizon Research en Printables
I designed and built this 6-Axis Robotic Arm from the ground up. PDF assembly manual included.
Licencia
Solo uso personalCC BY-NC 4.0 — Atribución, no comercial
Puedes imprimirlo y modificarlo para uso personal dando crédito. No se permite vender las impresiones.
Al descargar aceptas respetar la licencia y dar crédito a Event Horizon Research.
Archivos (36)
- BicepTricep.stl STL · 19,3 MB
- HalfBicepTricep.stl STL · 12,2 MB
- LongerCoupler.stl STL · 35,7 MB
- WristMount.stl STL · 312 KB
- Forearm.stl STL · 17,4 MB
- HandMount.stl STL · 222 KB
- HandMountShaft.stl STL · 255 KB
- PlanetV2_1.stl STL · 4,3 MB
- PlanetV2_3.stl STL · 4,3 MB
- ShoulderGearStage2.stl STL · 1,4 MB
- ShoulderGearV2Limiter.stl STL · 208 KB
- Spacer.stl STL · 81 KB
- ShoulderGearV2Sun2.stl STL · 2,2 MB
- ShoulderGearV2.stl STL · 4,7 MB
- PlanetV2_2.stl STL · 4,3 MB
- ElbowGearV2Limiter.stl STL · 208 KB
- Spacer.stl STL · 76 KB
- ElbowPlanet3.stl STL · 4,1 MB
- ElbowPlanet1.stl STL · 4,0 MB
- ElbowPlanet2.stl STL · 4,0 MB
- ElbowMount.stl STL · 4,0 MB
- ElbowSun.stl STL · 2,1 MB
- ElbowStage2.stl STL · 4,2 MB
- Bearing-Housing.stl STL · 156 KB
- Base.stl STL · 2,0 MB
- BaseMotorMount.stl STL · 398 KB
- BaseFoot.stl STL · 968 KB
- BaseSpacer.stl STL · 117 KB
- TPUFoot.stl STL · 48 KB
- BasePinion.stl STL · 1,7 MB
- Base_Flange.stl STL · 320 KB
- Elbow.stl STL · 32,5 MB
- Stepper Cap.stl STL · 163 KB
- Robotic Arm Instruction Manual.pdf PDF · 726 KB
- ControllerCode.txt TXT · 2 KB
- RobotBrainCode.txt TXT · 5 KB
- Categoría
- Tecnología
- Formatos
- STL, PDF, TXT
- Descargas
- 3,983
- Publicado
Sobre este modelo
I believe that robotics has not permeated every day life because of the large costs generally associated with it, so I wanted to design 6-Axis Robotic Arm from the ground up. I wanted it to use 3D printing as much as possible. Everything except mounting hardware, electronics, and motors is 3D printed. I've designed only one robotic arm before, and learned a lot of lessons that this new one takes into account. This arm is much more robust and capable, and includes the ability to be controlled wirelessly through radio communication. I have included an assembly manual, again a first for me, so I hope that helps anyone interested. I have also attached the text files of the code I use to control the robot. It is a modified version of the RFM69 example code. Make sure to add the necessary libraries, and wire the components in accordance with the code if you want to use it directly. If you have any questions, feel free to reach out and I will help you with what I can. A couple notes: I have not included an end effector since everyone's requirements are different. I encourage everyone to design their own. I also have not included the controller. It didn't turn out as well as I had hoped (aesthetically), so I have decided to skip on including it. I hope you enjoy this project! A video to it running is on Reddit here: https://www.reddit.com/r/3Dprinting/comments/1azw67y/3d_printed_6axis_robot/?utm_source=share&utm_medium=web2x&context=3
Descripción original del autor, publicada en Printables.